Gen Li

Full Professor @ HNU

prof_pic.jpg

Email: ligen [at] g.skku.edu

教师主页 · Faculty Profile

I am a incoming Professor at the School of AI and Robotics, Hunan University. My research focuses on building reliable, efficient, and human-centered embodied intelligence that can perceive, reason, and act in the physical world. I am broadly interested in embodied AI, robot learning, multimodal foundation models, efficient AI, and human-robot interaction.

Previously, I was a Research Fellow at Nanyang Technological University, working with Jianfei Yang. I received my PhD in Robotics and Autonomous Systems from The University of Edinburgh, supervised by Laura Sevilla and co-supervised by Timothy Hospedales. My research has been supported by Google DeepMind and Stability AI, where I collaborated with Deqing Sun and Varun Jampani, and by Huawei Noah’s Ark Lab in London, where I worked as a student researcher with Kun Shao.

📢 I am always looking for highly motivated PhD and master’s students, postdocs, research assistants/interns, visiting scholars, and research collaborators. If you are interested in working together, please feel free to reach out by email.


News

Oct 2026 🚩 Our survey preprint on Affordance Learning for Embodied AI is now available!
Oct 2026 📖 Invited to serve as a Reviewer for Nature Reviews Computing.
Sep 2026 🎉 Evo-Depth, Feedback-WM, and FLASH are accepted to NeurIPS 2026!
Sep 2026 🎉 UCA-Flow and ADAPT are accepted to CoRL 2026!
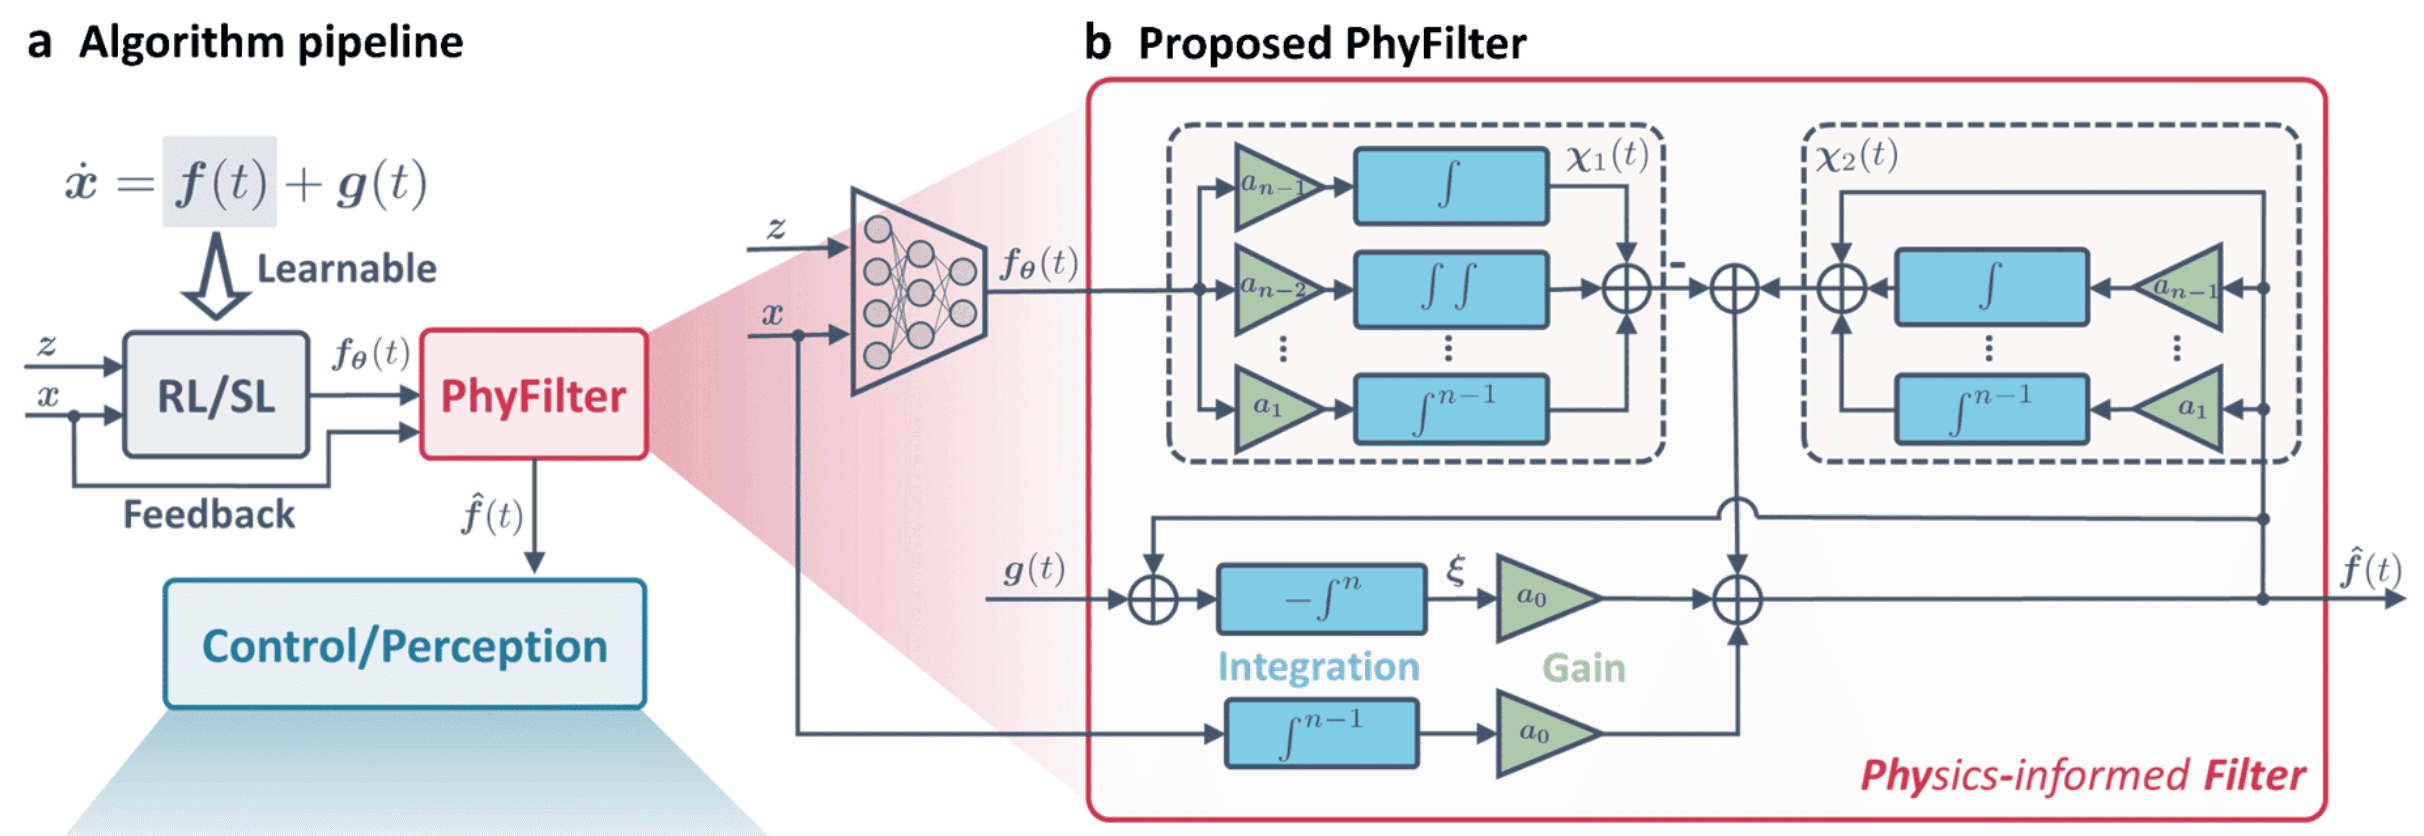
Aug 2026 🎉 PhyFilter is accepted by Nature Portfolio Robotics!
Aug 2026 🎉 World Model for Robot Learning: A Comprehensive Survey is accepted by IJRR!
May 2026 🚩 Our latest survey, World Model for Robot Learning, is now out on arXiv!
Apr 2026 🎉 A2A Flow Matching is accepted to RSS 2026!


Selected Publications

*/† indicates equal contribution/advising Full publication list on Google Scholar

Showing 11 publications
  1. Preprint
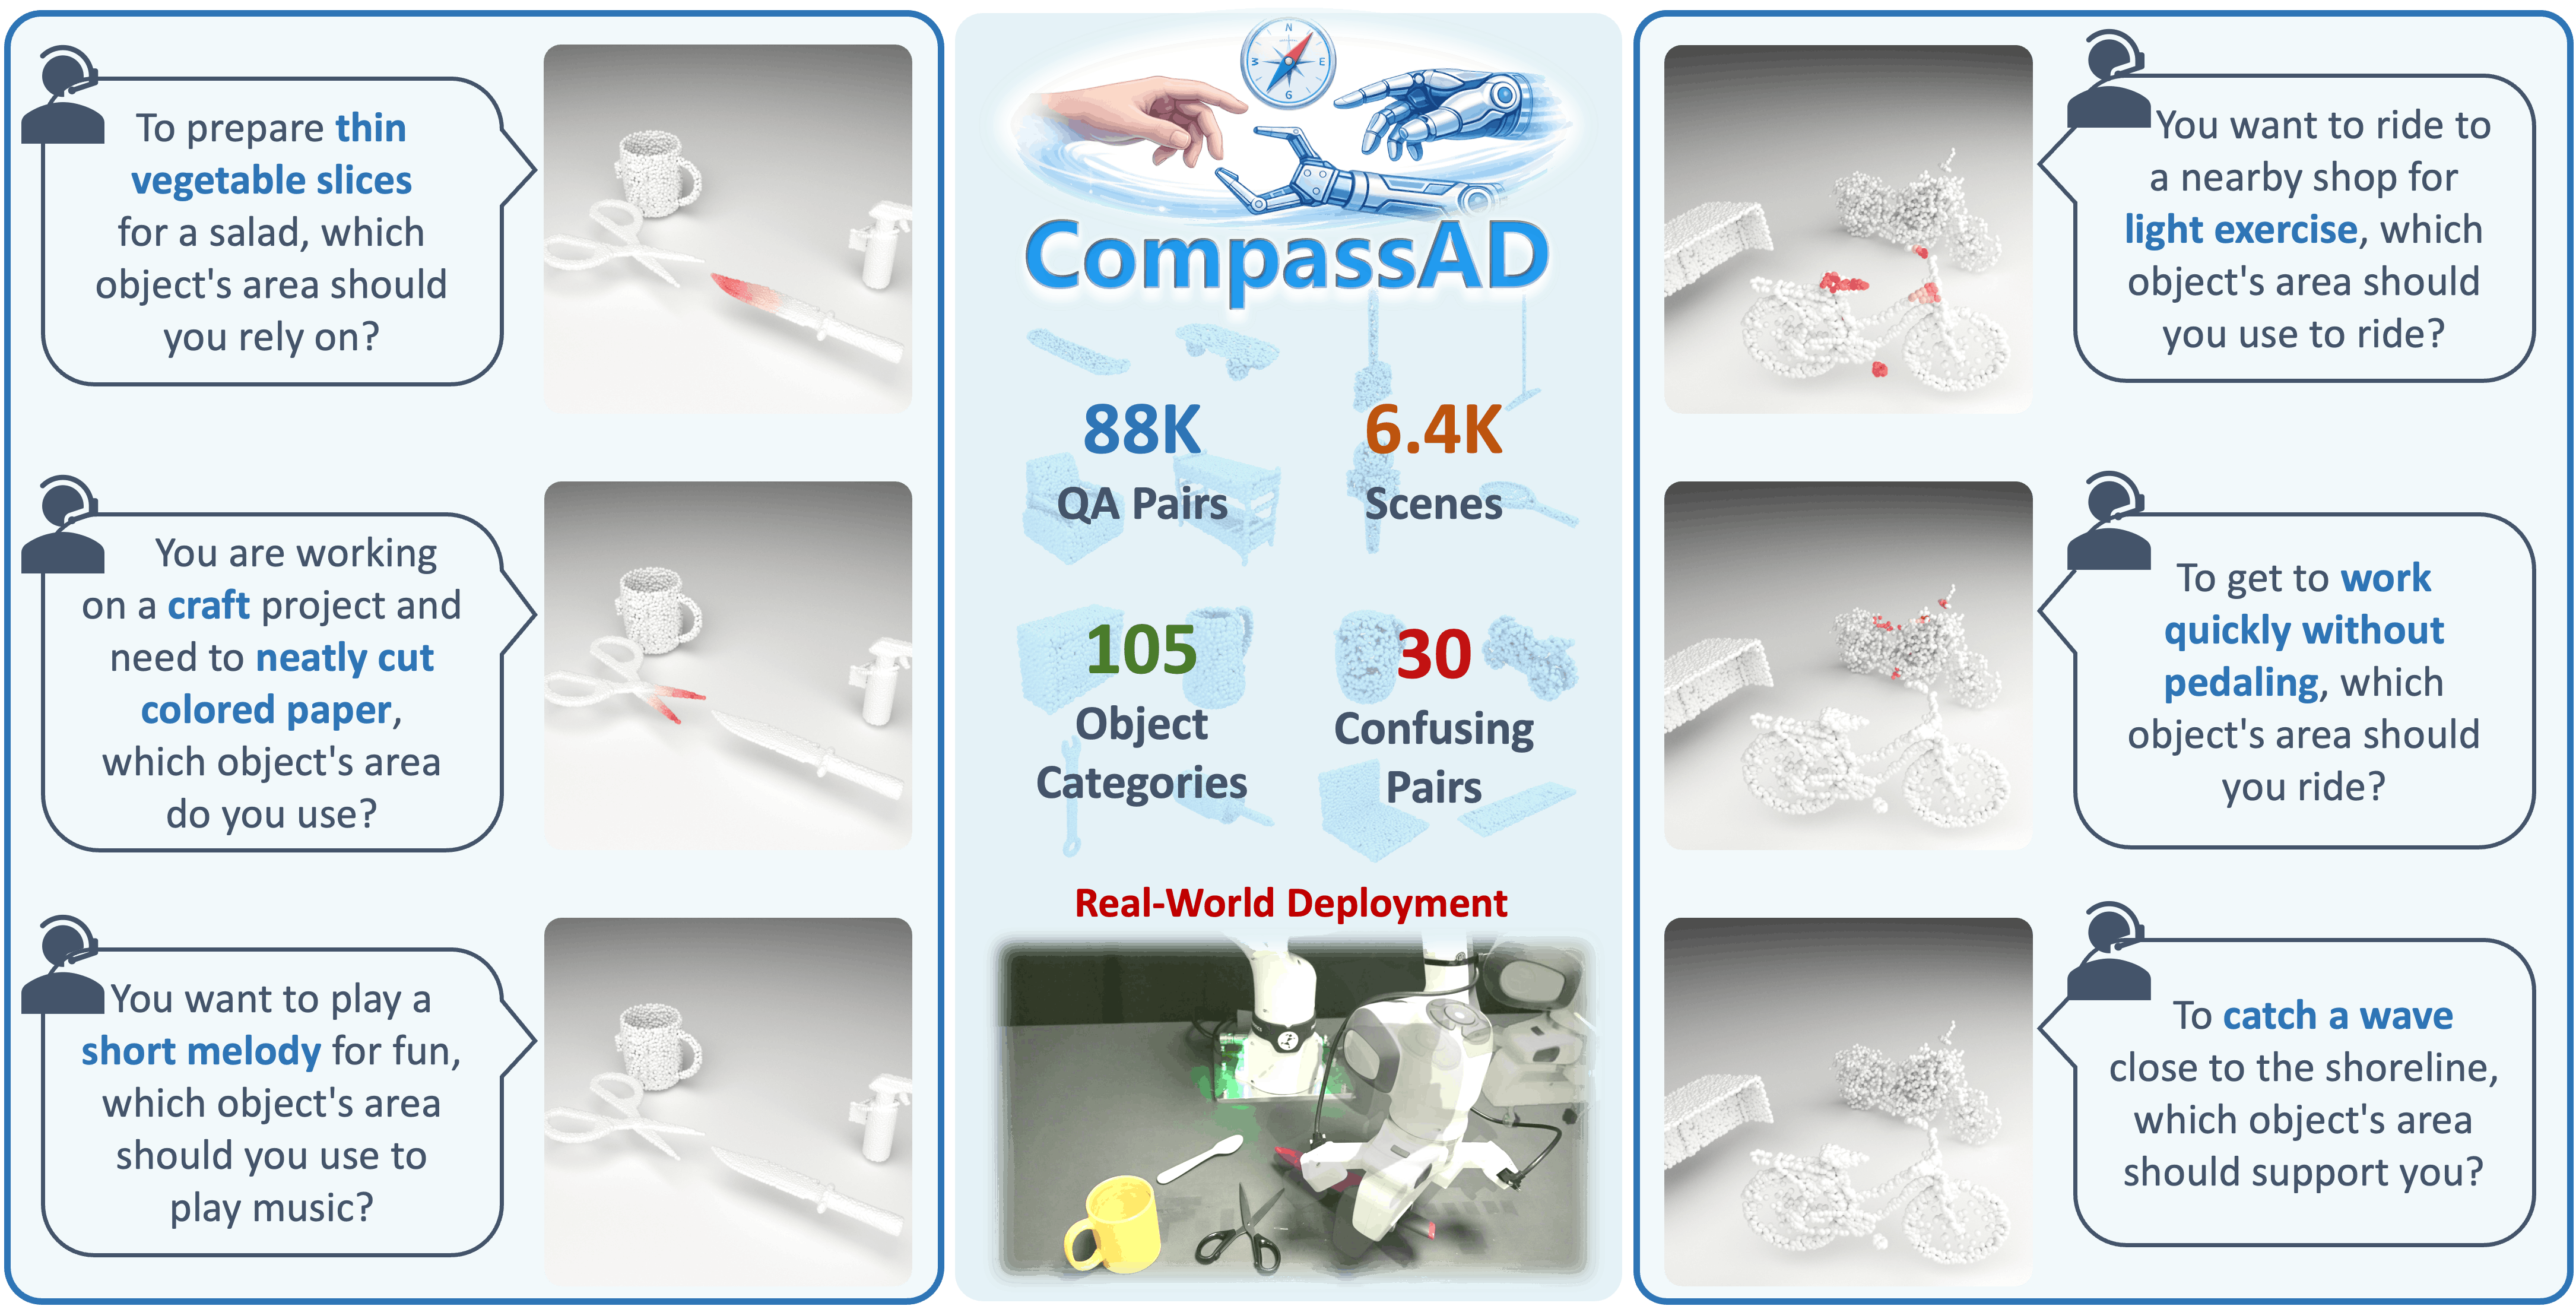
    affordance-timeline.png
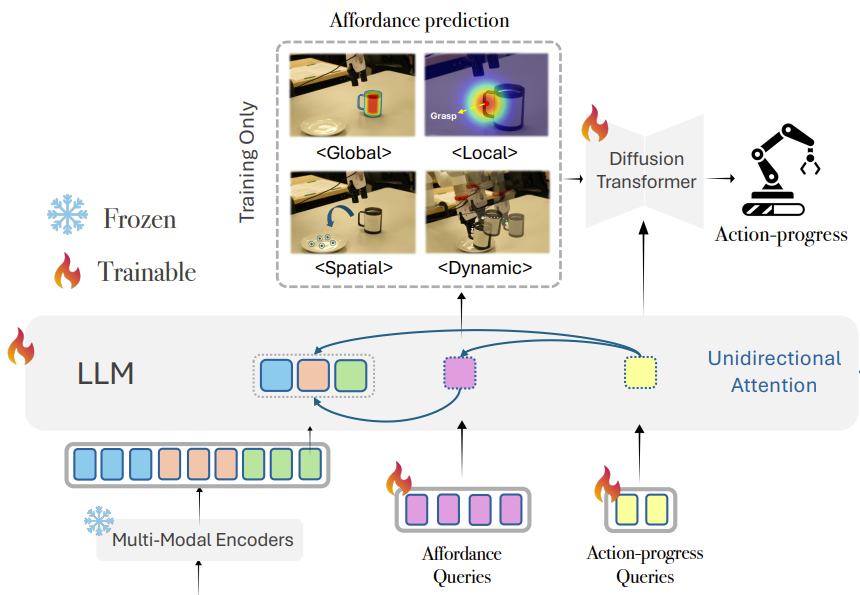
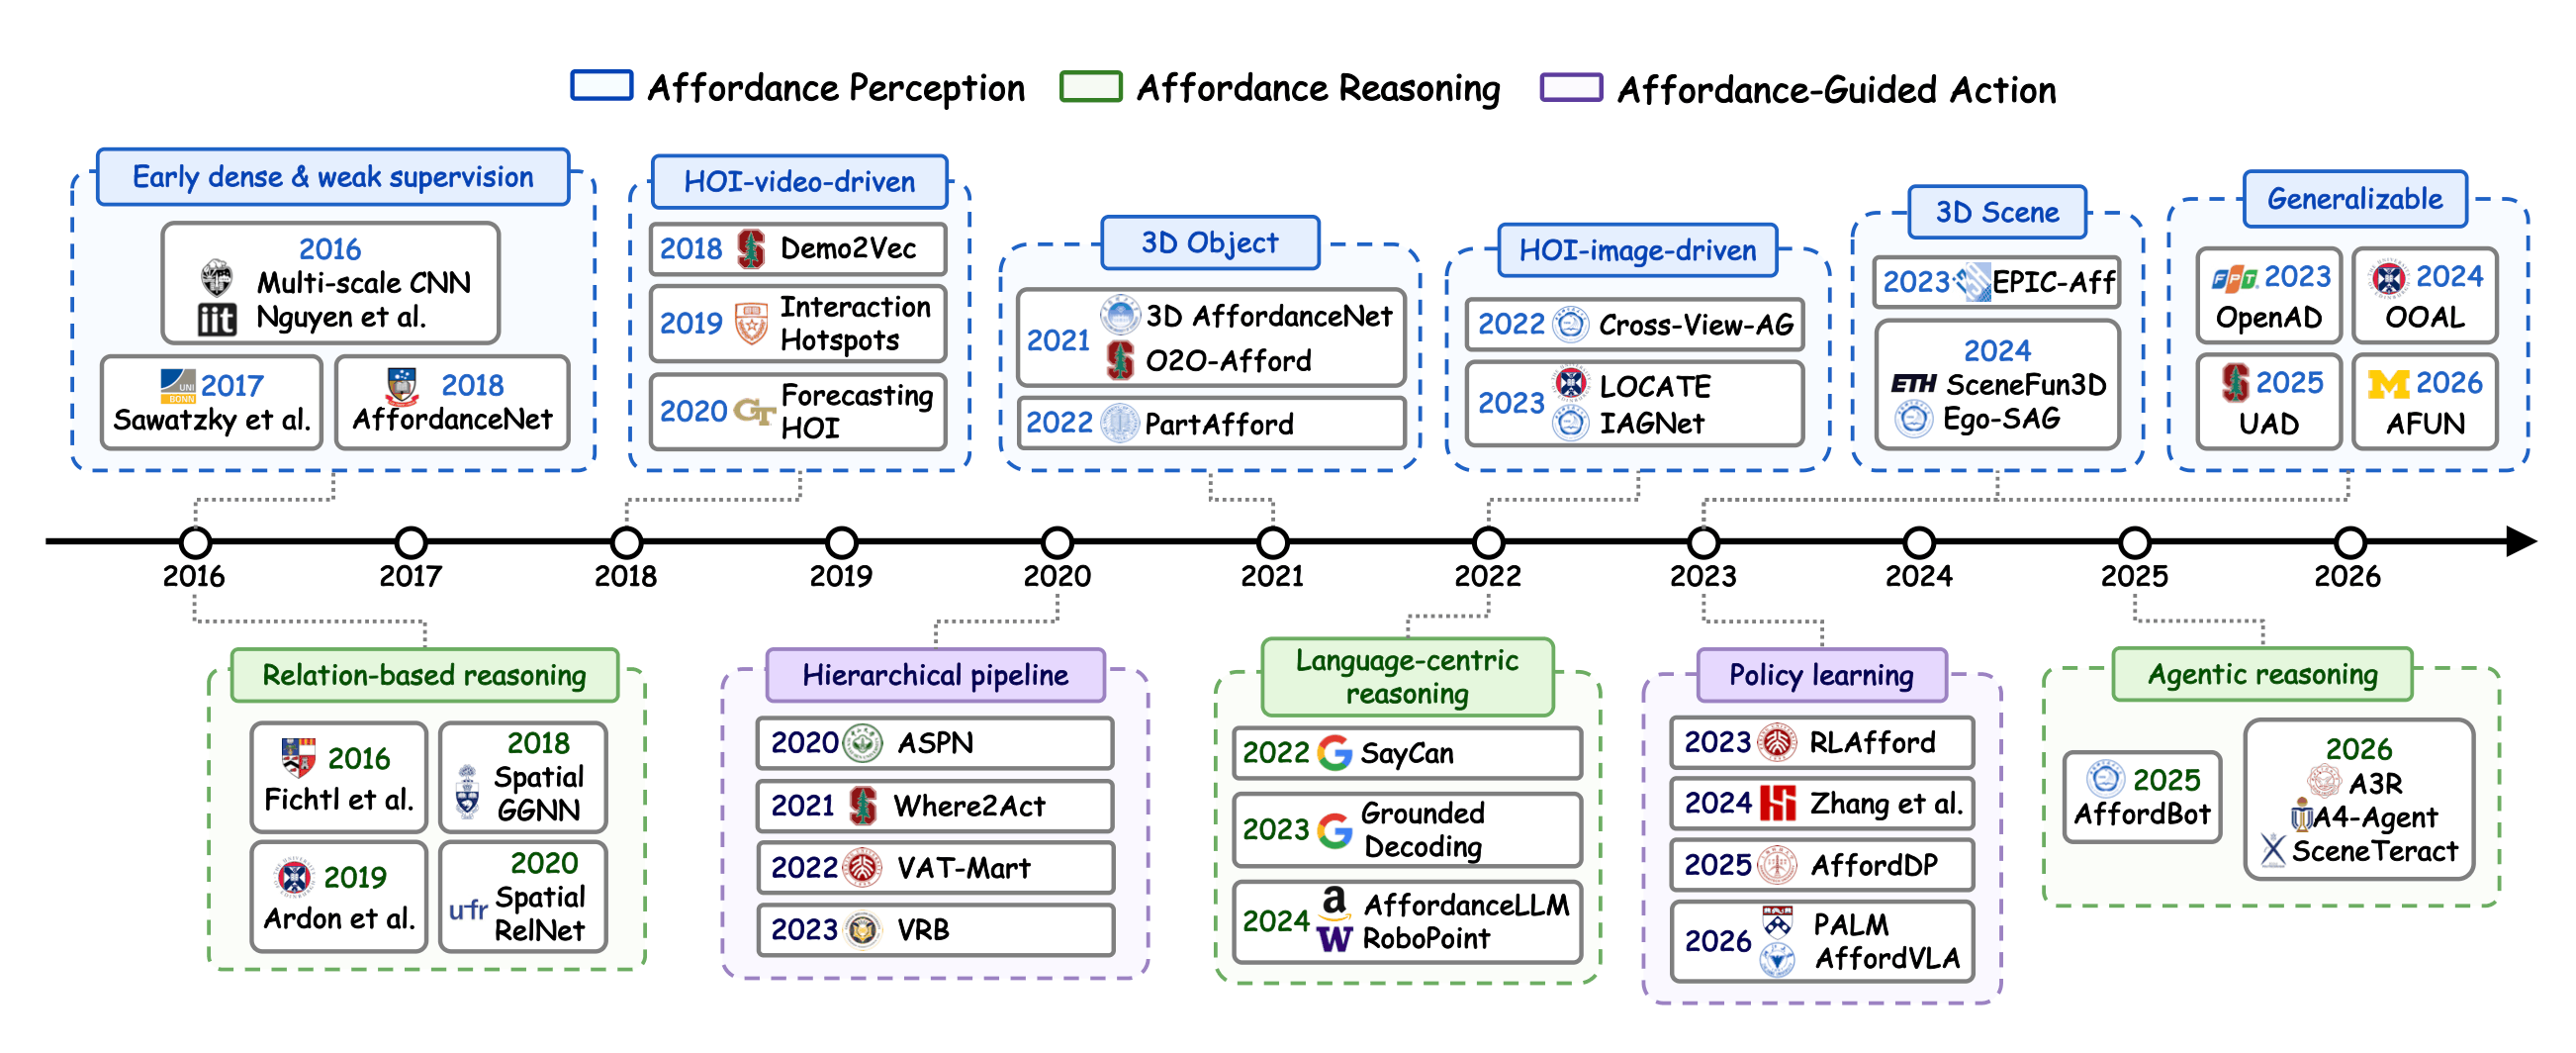
    From Passive Perception to Active Interaction: A Survey of Affordance Learning for Embodied AI
    Gen Li, Hanqing Wang, Jingliang Li, Yifan Han, Jindou Jia, Tao Lin, Yuanzhe Liu, Yutong Wang, Bo Zhao, Fangqiang Ding, Anh Nguyen, Laura Sevilla-Lara, Huazhe Xu, Gregory S. Chirikjian, Marc Pollefeys, Oier Mees, Hui Xiong, and Jianfei Yang
    Preprints.org, 2026
  2. NeurIPS’26
    evo-depth.png
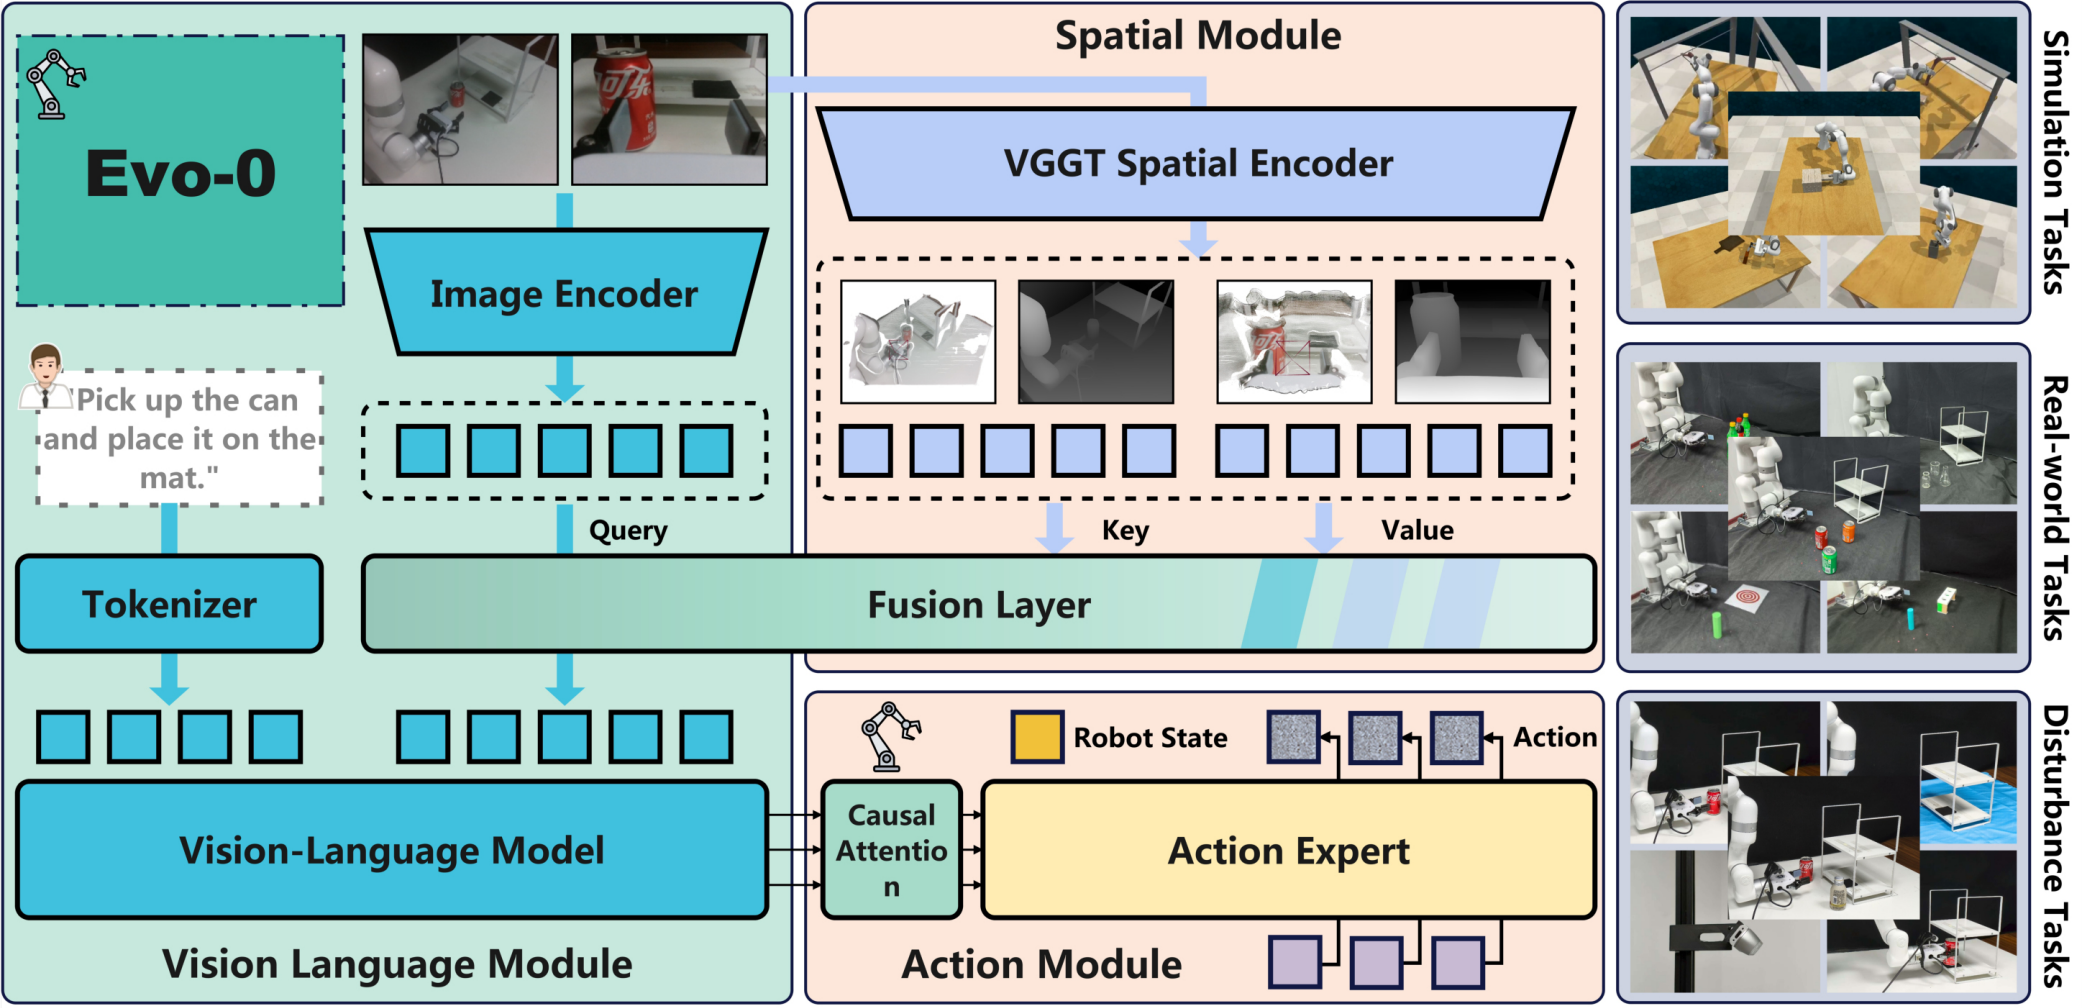
    Evo-Depth: A Lightweight Depth-Enhanced Vision-Language-Action Model
    Tao Lin, Yuxin Du, Jiting Liu, Nuobei Zhu, Yunhe Li, Yuqian Fu, Yinxinyu Chen, Hongyi Cai, Zewei Ye, Bing Cheng, Kai Ye, Yiran Mao, Yilei Zhong, MingKang Dong, Junchi Yan, Gen Li†, and Bo Zhao†
    In Conference on Neural Information Processing Systems, 2026
  3. IJRR
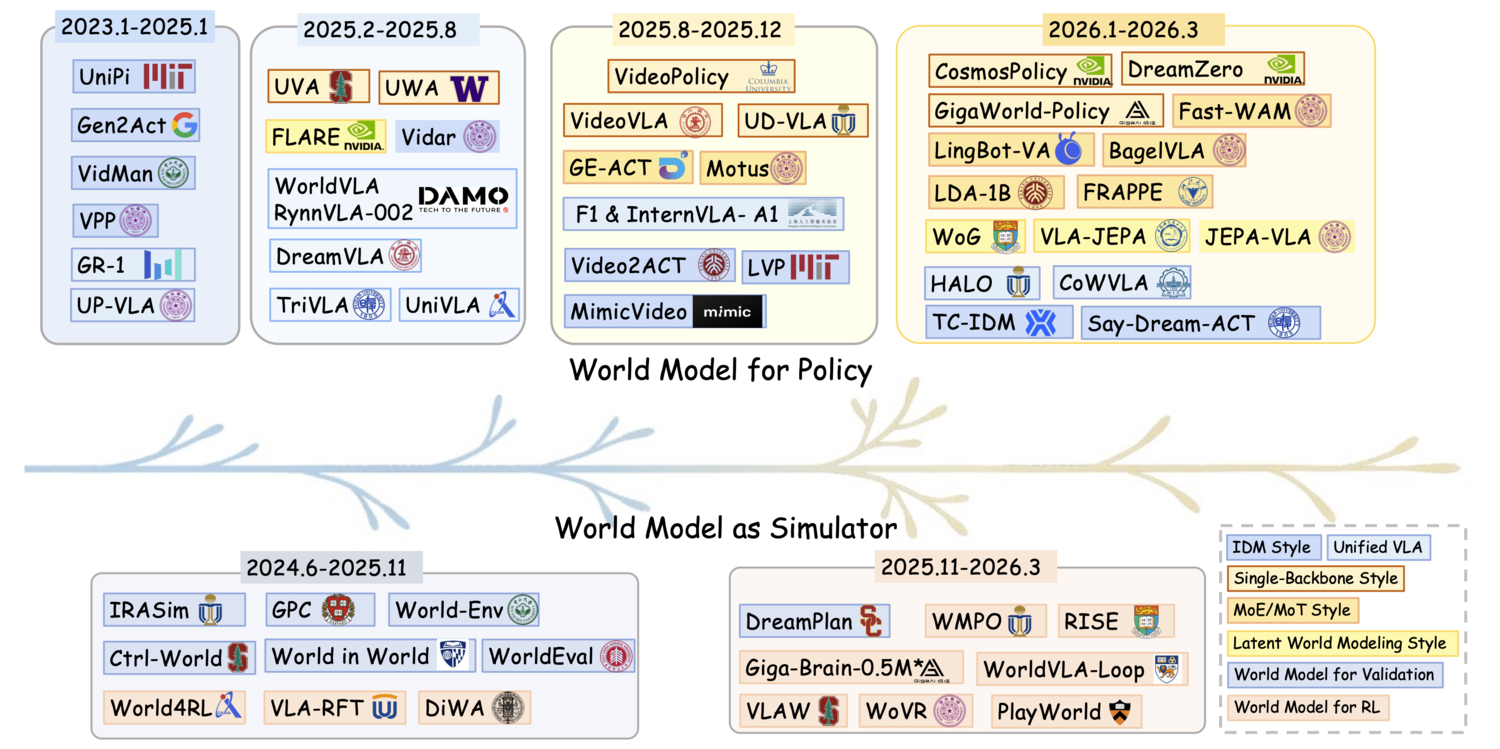
    wm-survey.png
    World Model for Robot Learning: A Comprehensive Survey
    Bohan Hou*, Gen Li*, Jindou Jia*, Tuo An*, Xinying Guo*, Sicong Leng, Haoran Geng, Yanjie Ze, Tatsuya Harada, Philip Torr, Oier Mees, Marc Pollefeys, Zhuang Liu, Jiajun Wu, Pieter Abbeel, Jitendra Malik, Yilun Du, and Jianfei Yang
    International Journal of Robotics Research, 2026
  4. RSS’26
    a2a.webp
    Action-to-Action Flow Matching
    Jindou Jia*, Gen Li*, Xiangyu Chen, Tuo An, Yuxuan Hu, Jingliang Li, Xinying Guo, and Jianfei Yang
    In Robotics: Science and Systems, 2026
  5. CVPR’26
    evo1.webp
    Evo-1: Lightweight Vision-Language-Action Model with Preserved Semantic Alignment
    Tao Lin, Yilei Zhong, Yuxin Du, Jingjing Zhang, Jiting Liu, Yinxinyu Chen, Encheng Gu, Ziyan Liu, Hongyi Cai, Yanwen Zou, Lixing Zou, Zhaoye Zhou, Gen Li†, and Bo Zhao†
    In IEEE/CVF Conference on Computer Vision and Pattern Recognition, 2026
  6. AAAI’26
    mask2iv.webp
    Mask2IV: Interaction-Centric Video Generation via Mask Trajectories
    Gen Li, Bo Zhao, Jianfei Yang, and Laura Sevilla-Lara
    In AAAI Conference on Artificial Intelligence, 2026
  7. ICCV’25
    affgrasp.webp
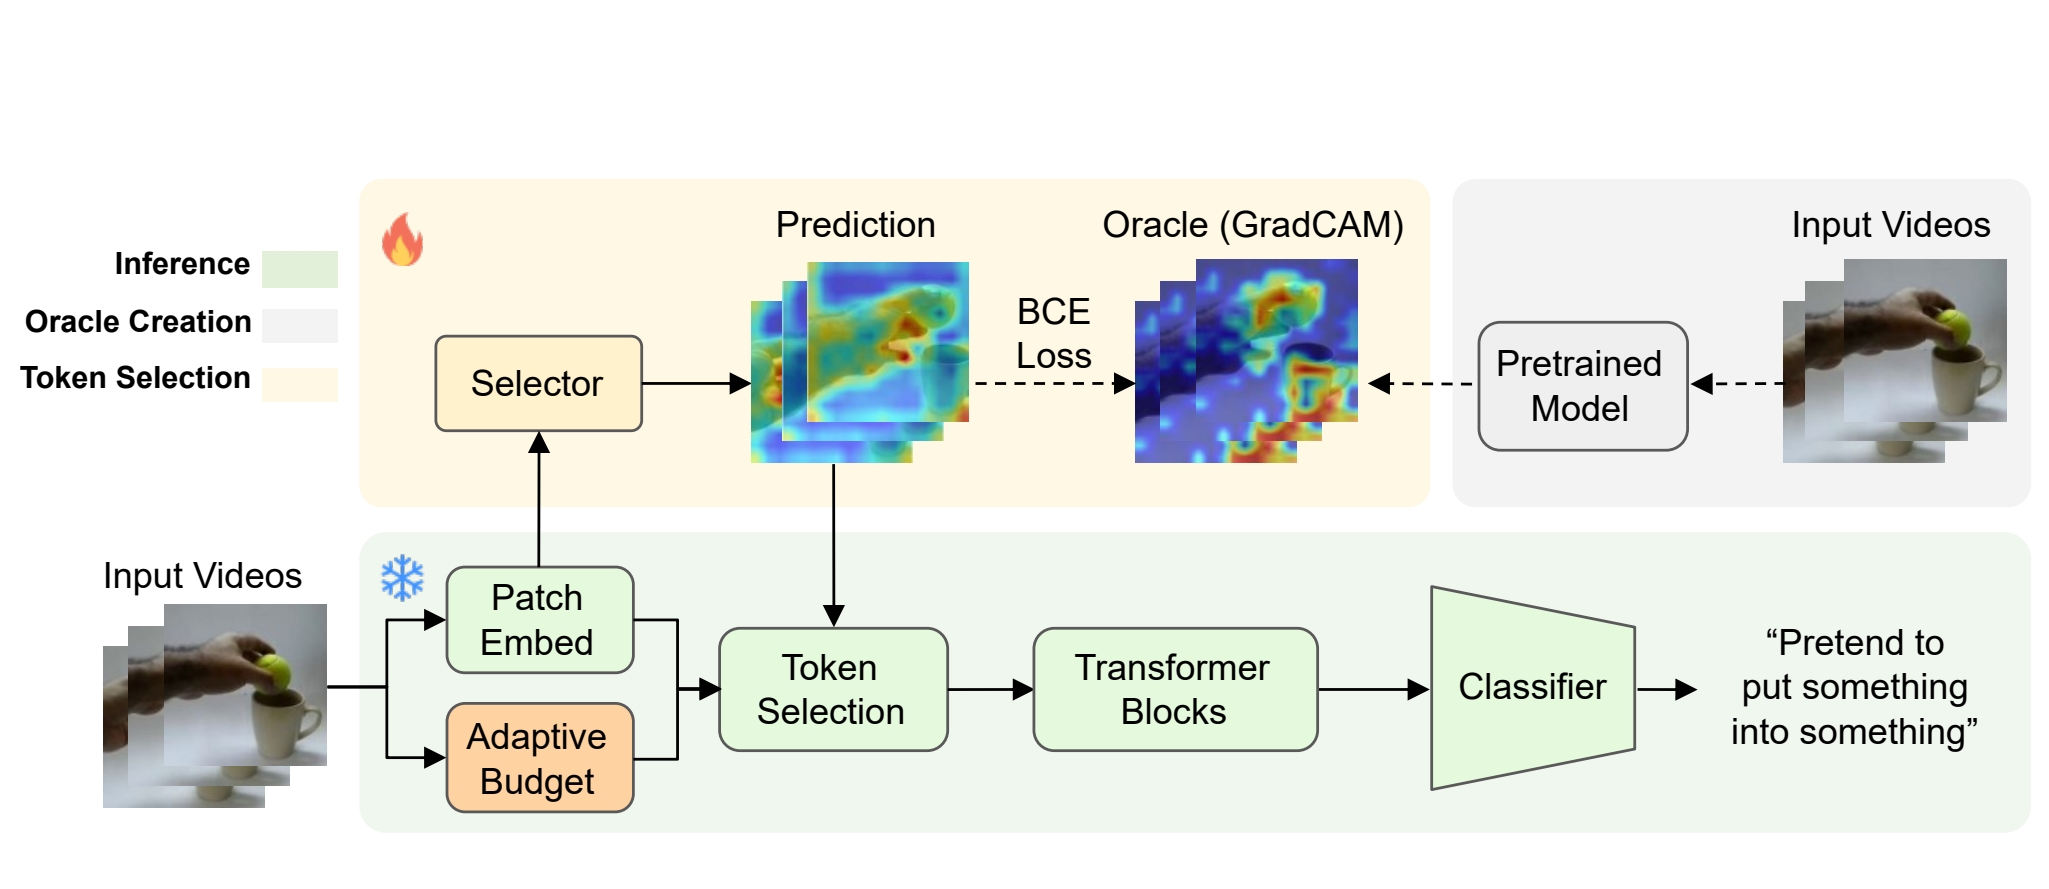
    Learning Precise Affordances from Egocentric Videos for Robotic Manipulation
    Gen Li, Nikolaos Tsagkas, Jifei Song, Ruaridh Mon-Williams, Sethu Vijayakumar, Kun Shao, and Laura Sevilla-Lara
    In IEEE/CVF International Conference on Computer Vision, 2025
  8. NMI
    ellmer.webp
    Embodied Large Language Models Enable Robots to Complete Complex Tasks in Unpredictable Environments
    Ruaridh Mon-Williams†, Gen Li†, Ran Long, Wenqian Du, and Chris Lucas
    Nature Machine Intelligence, 2025
  9. CVPR’24
    ooal.png
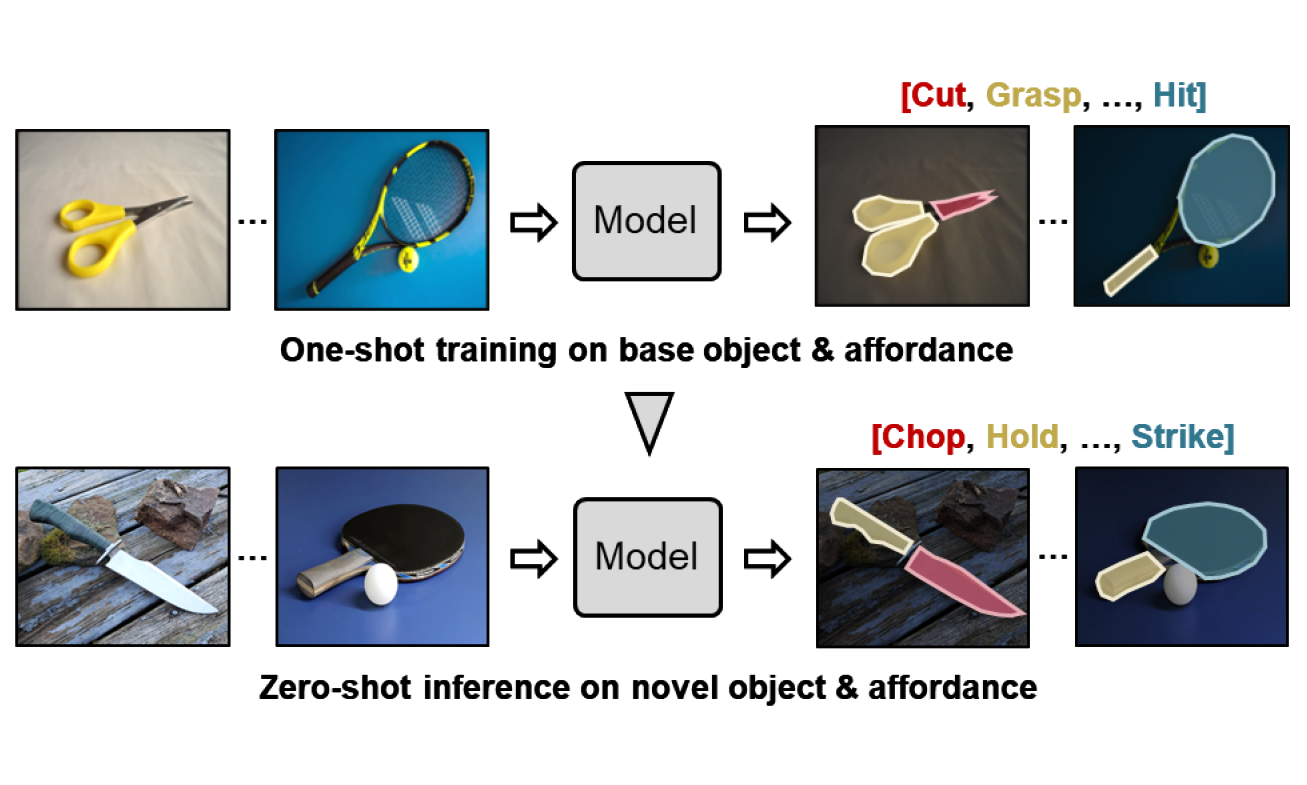
    One-Shot Open Affordance Learning with Foundation Models
    Gen Li, Deqing Sun, Laura Sevilla-Lara, and Varun Jampani
    In IEEE/CVF Conference on Computer Vision and Pattern Recognition, 2024
  10. CVPR’23
    LOCATE.png
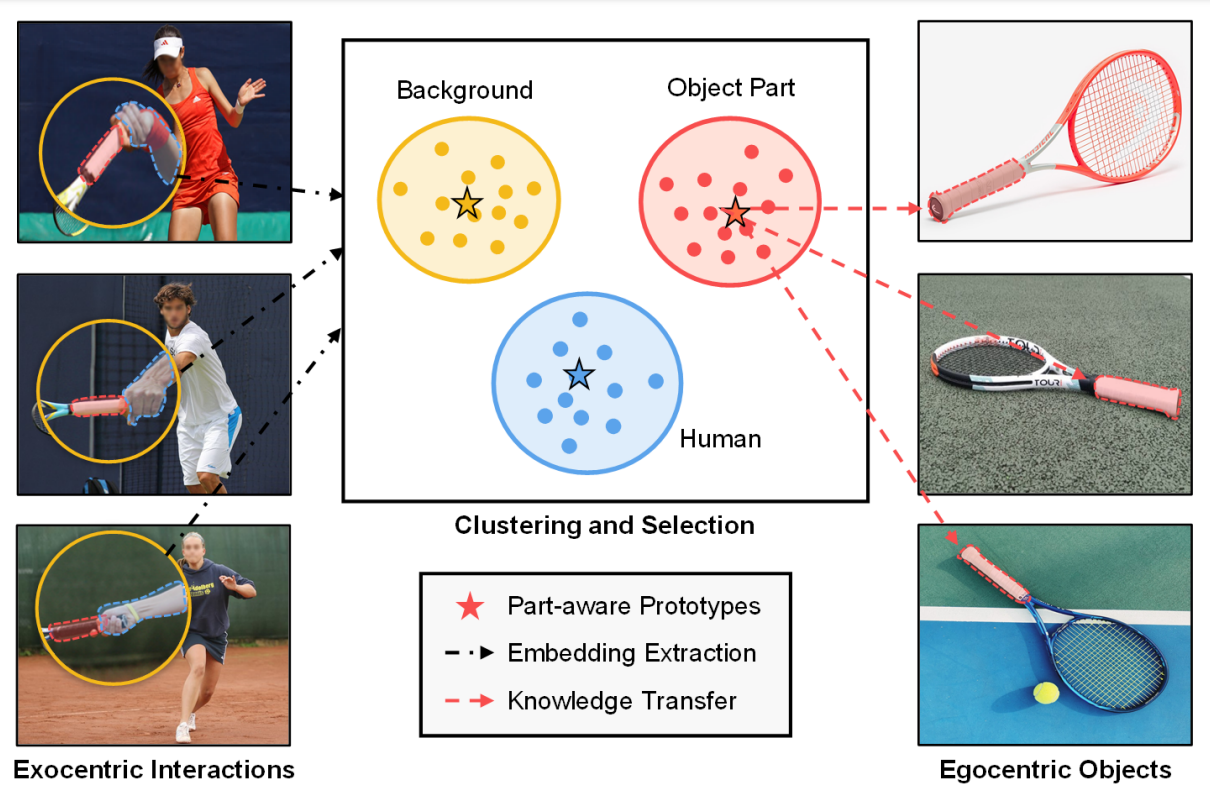
    LOCATE: Localize and Transfer Object Parts for Weakly Supervised Affordance Grounding
    Gen Li, Varun Jampani, Deqing Sun, and Laura Sevilla-Lara
    In IEEE/CVF Conference on Computer Vision and Pattern Recognition, 2023
  11. CVPR’21
    ASGNet.png
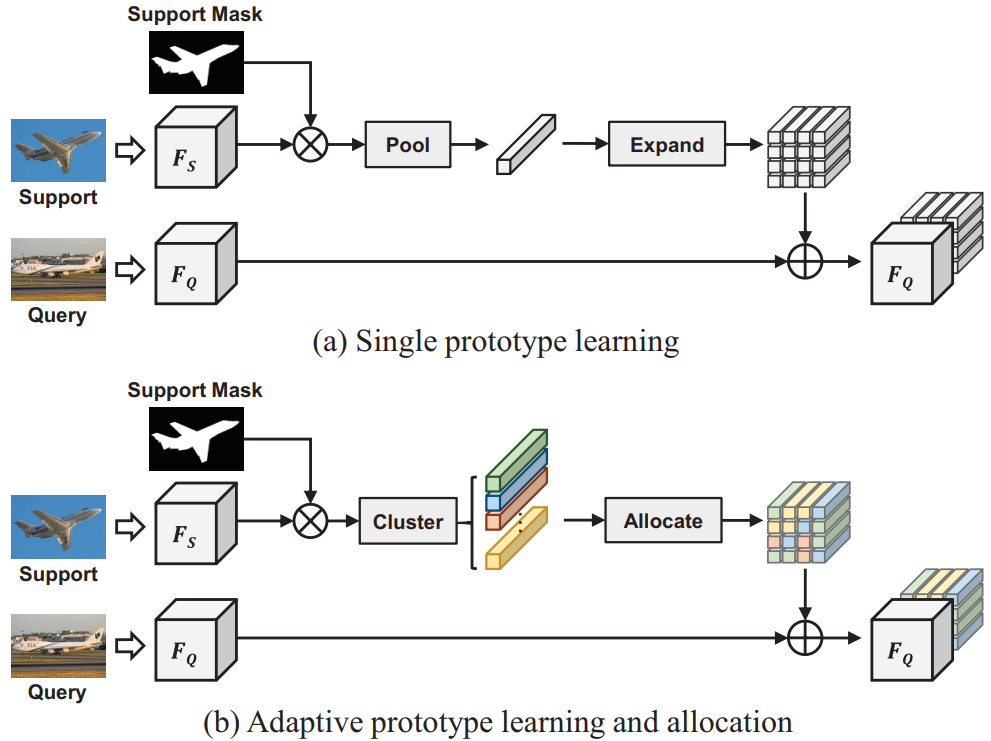
    Adaptive Prototype Learning and Allocation for Few-Shot Segmentation
    Gen Li, Varun Jampani, Laura Sevilla-Lara, Deqing Sun, Jonghyun Kim, and Joongkyu Kim
    In IEEE/CVF Conference on Computer Vision and Pattern Recognition, 2021


Academic Service

  • Area Chair: NeurIPS 2026, BMVC 2026
  • Journal Reviewer: Nature Machine Intelligence, Nature Reviews Computing, TIP, etc.
  • Conference Reviewer: CVPR, ICCV, ECCV, NeurIPS, ICLR, RSS, CoRL, ICRA, IROS, AAAI, etc.